Our success relies on you, so you can rely on us.
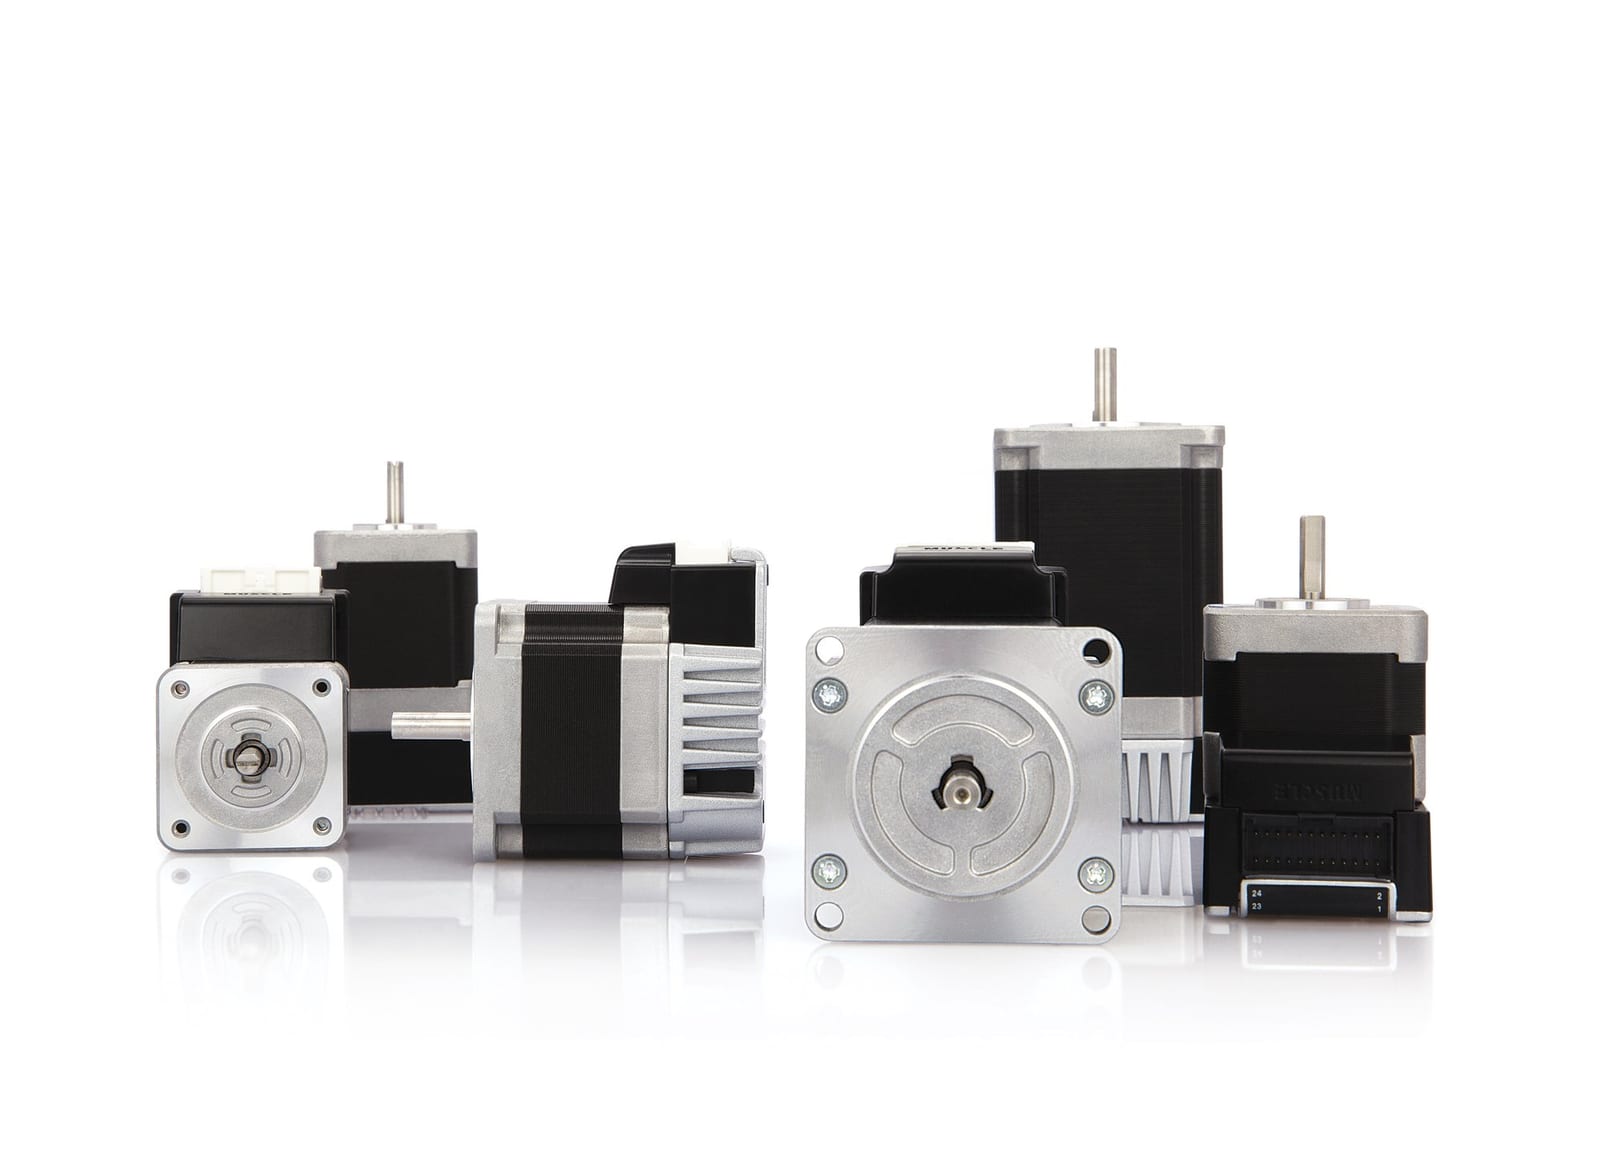
Myostat Motion Control provides automation components, integrated servo and stepper motors, and engineering support. Cool Muscle CM1 and CM2 integrated servos, paired with planetary and right-angle gearboxes, rodless ballscrew stages, rack-and-pinion actuators, SR joints, and the cables to tie it all together.
One NEMA 17 package — motor, drive, encoder, controller
The CM1-C is the workhorse of the Cool Muscle line: 0.53 N·m peak from a 42 mm frame, 50,000 ppr closed-loop control, and no separate drive cabinet. Program it directly in Cool Muscle Language over RS-485.
A servo that runs the machine, not just the axis
CM3+ adds a logic bank alongside the motion bank, so sequencing, I/O handling and decision-making happen on the motor itself. For simple cells it can remove the PLC from the bill of materials entirely.
Rack and pinion when stroke length can't be fixed
Ball screws set your travel at design time. The RA17 drives a stainless rack through a hardened pinion — 60 N continuous, 125 mm of travel per standard rack, and any length you like if you specify a custom one.
Three axes of rotation with no measurable clearance
Hephaist spherical rolling joints replace sliding contact with preloaded rolling elements. The result is near-zero friction and zero backlash — the reason they end up in semiconductor and optical positioning stages.
Hypoid gearing where a right angle has to stay quiet
The HY series puts the offset hypoid tooth form to work: higher contact ratio than spiral bevel, which means smoother torque transfer and less noise at the same ratio and frame size.
Helical planetary gearing, 97 % efficient under load
The ZS series trades straight-cut simplicity for helical tooth engagement — quieter running, higher torque density, and 3 arc-minutes of backlash in a 60 mm square body.
EtherCAT down to the motor, no drive cabinet in between
A dedicated EtherCAT body with a two-port switch and CiA-402 profile, so the servo joins the fieldbus directly. Control and drive power are separated, which keeps the network alive while the power stage is safely de-energised.
Ethernet/IP servos that speak your PLC's language
The CM1-T puts a native Ethernet/IP interface on the same 0.53 N·m NEMA 17 platform — a straightforward path onto Allen-Bradley and Rockwell architectures without a protocol gateway. Modbus TCP and CML over Ethernet run on the same hardware, so one motor covers PLC control, SCADA, and direct scripting.
Linear motion in a NEMA 11 footprint
The CSR-11 folds a lead screw into the servo itself — 100 N of thrust and 25.4 mm of travel from a 28 mm frame, with no coupling, no external screw, and nothing to align. Where a full actuator won't fit, this usually will.
Bench-test a CM3 before it ever sees the machine
The MYO37 development board breaks out the CM3's I/O, power and comms on a desktop, so programs can be written and proven before the motor is installed in an enclosure.
Not sure which part you need?
Describe your application in plain words — loads, sizes, motion, interface — and our product finder matches it against the full catalogue.
资料来源:企业官网公司简介(复核日期:2026-10-07)。